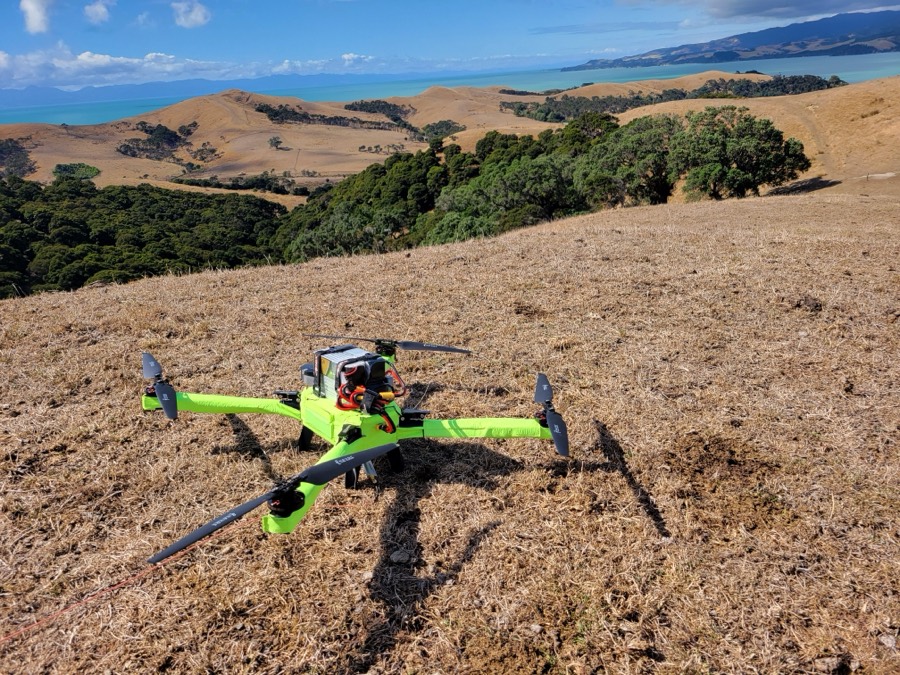
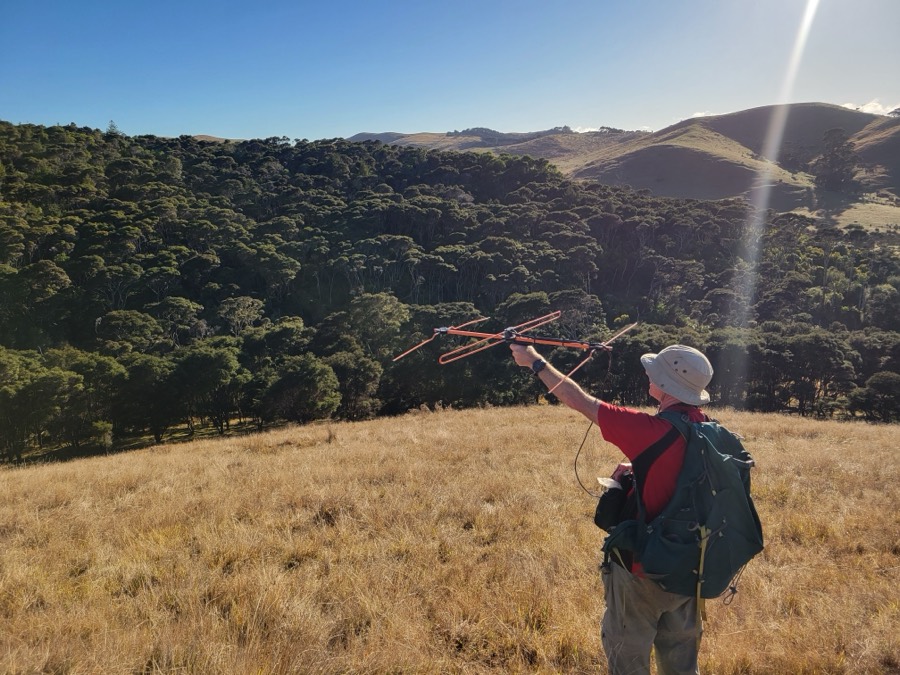
With Victoria University of Wellington and Massey University, UAV-RT achieved its first successful real-world wildlife localization — tracking wild kiwi across Ponui Island's terrain.


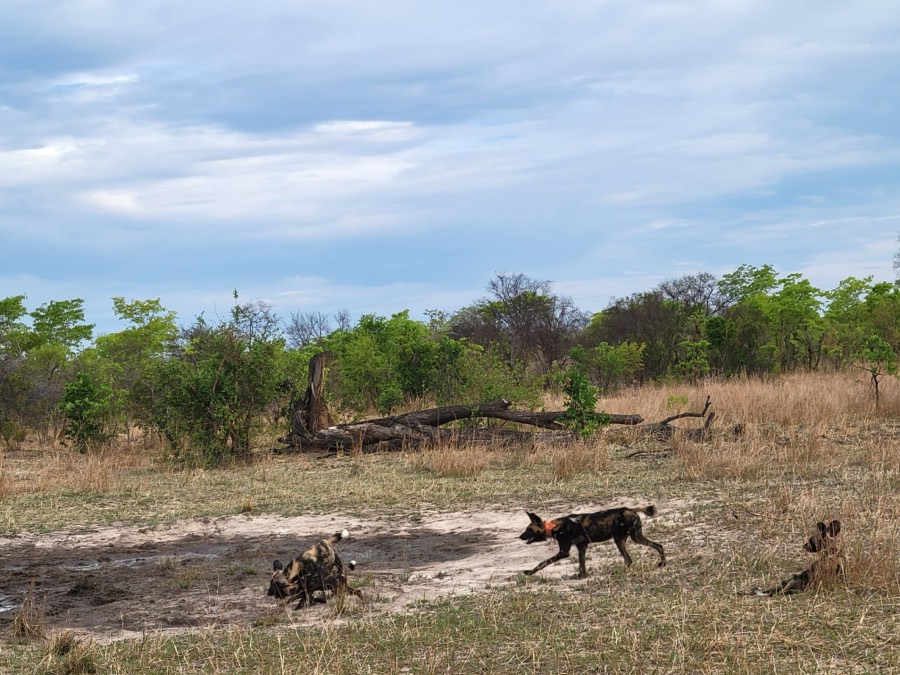
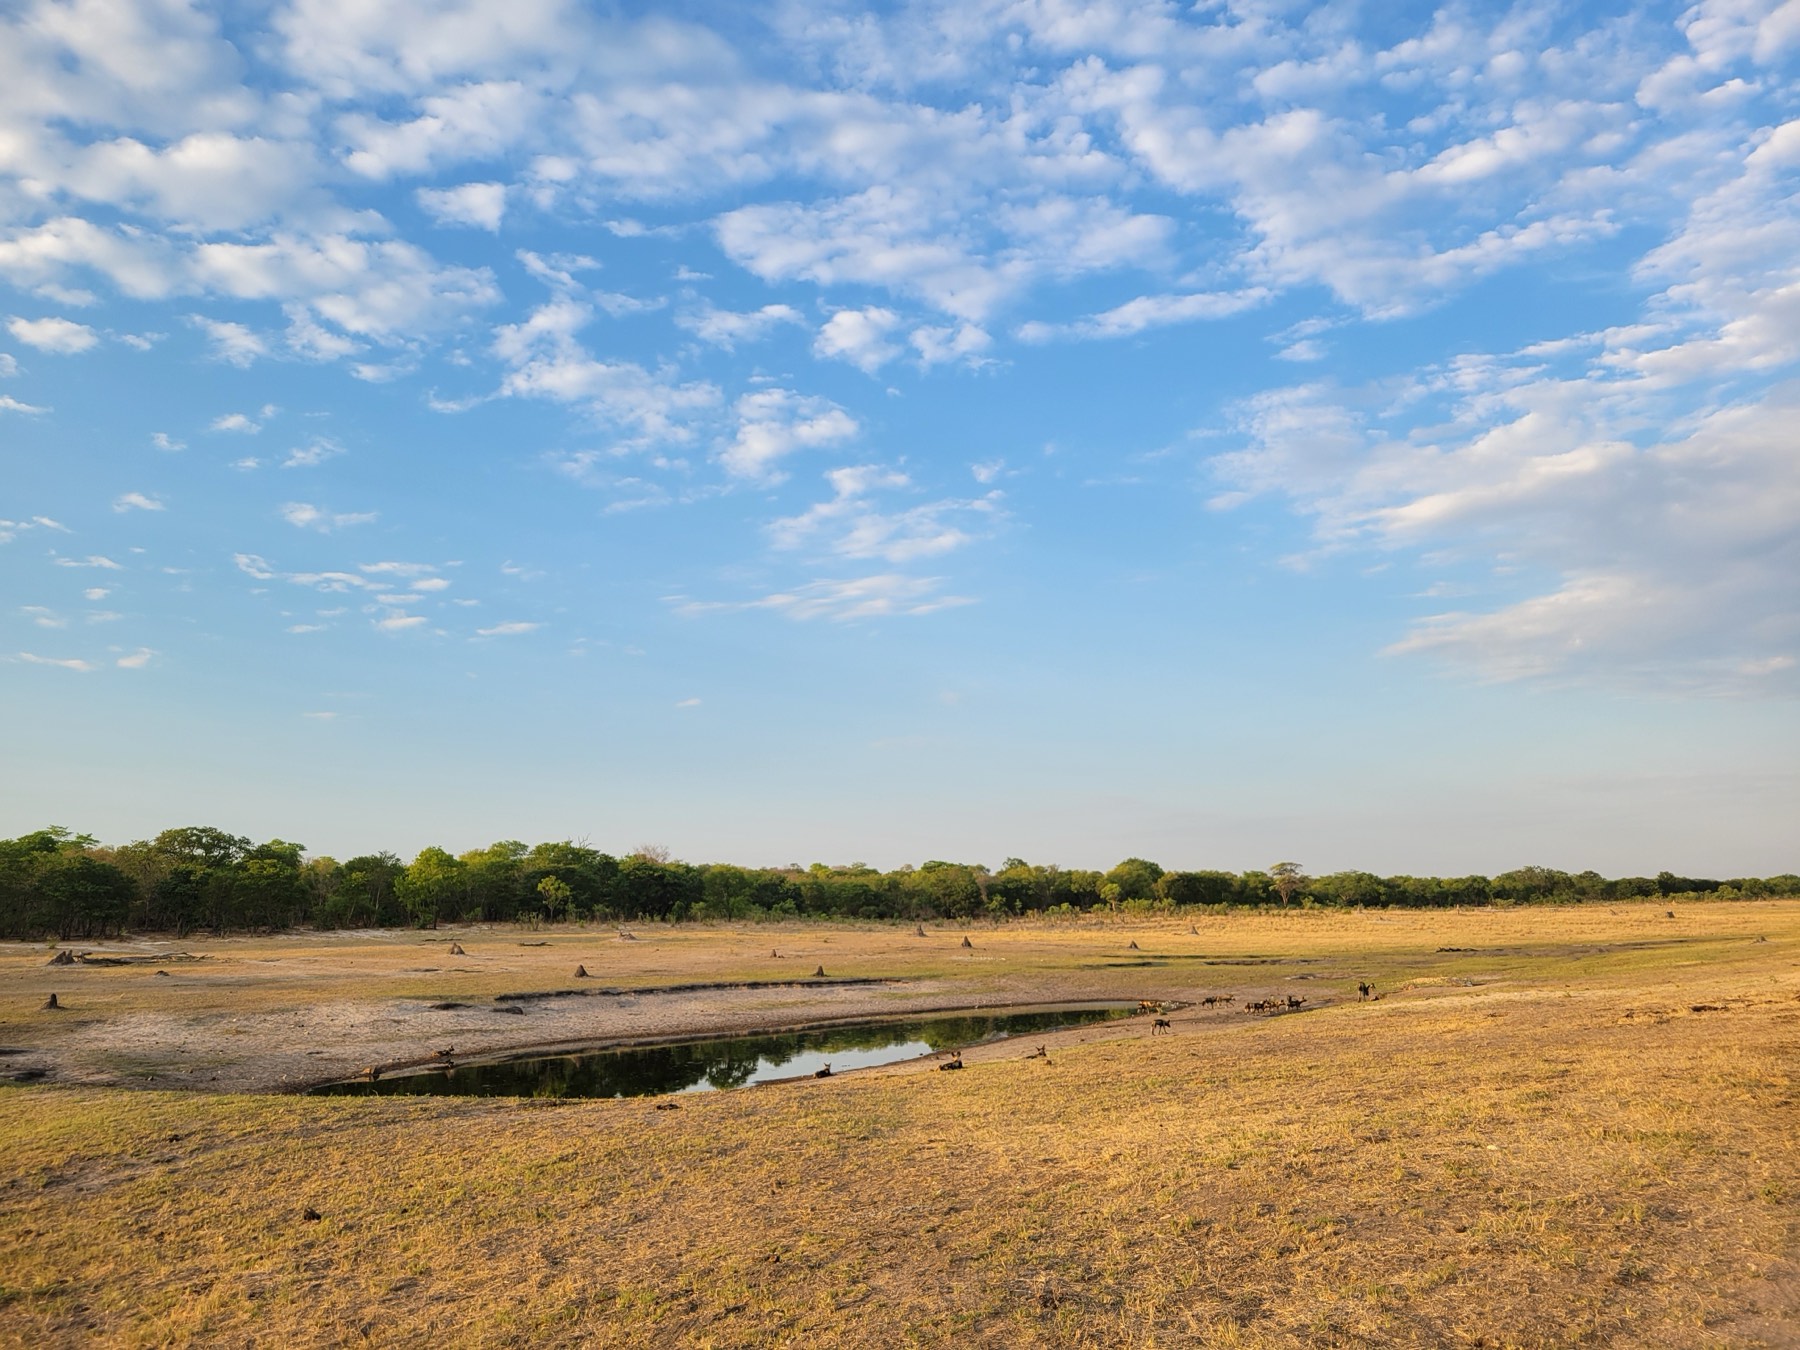
Working with Painted Dog Conservation, onboard noise engineering pushed detection range from roughly 1.5 km to 6–7 km — about 6x a ground tracker's range.
Supporting a pine marten reintroduction with the University of Cumbria, UAV-RT located two tagged martens that the ground survey team could not find.
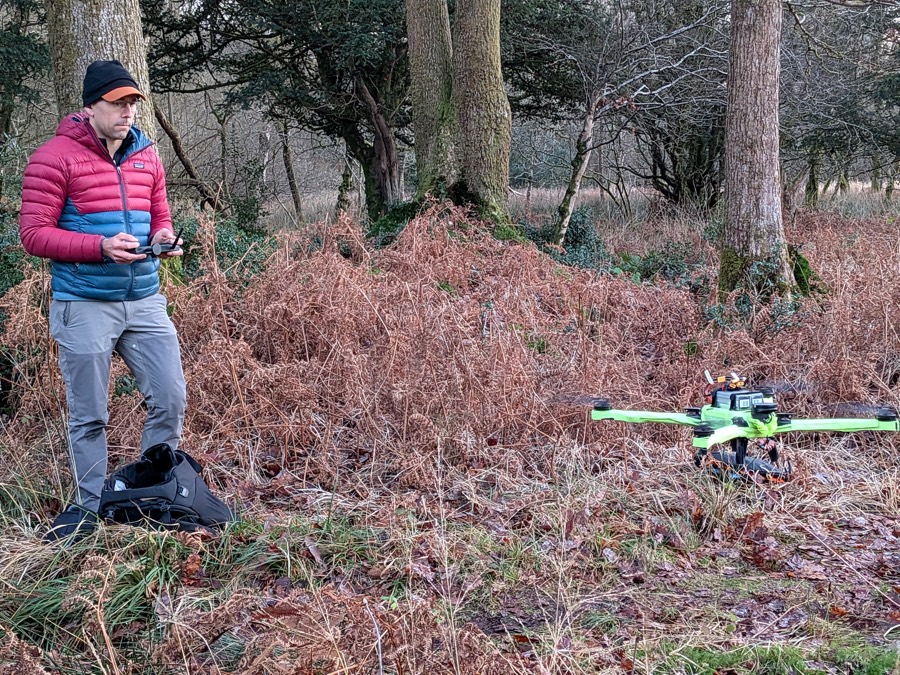
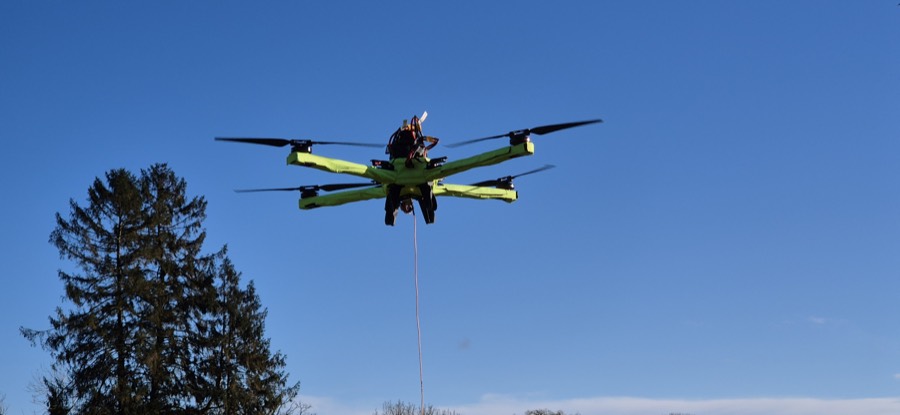
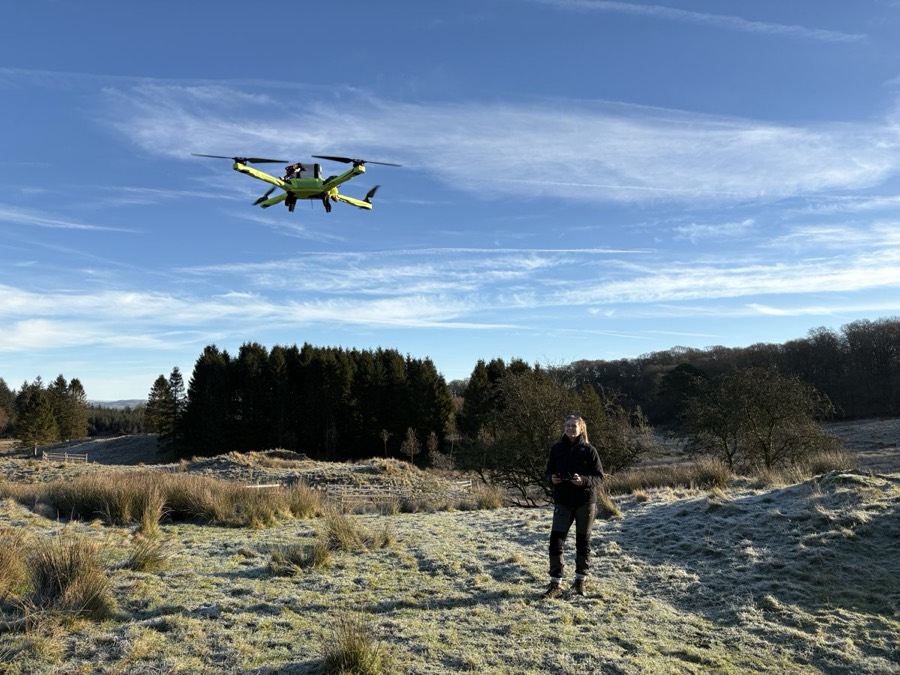
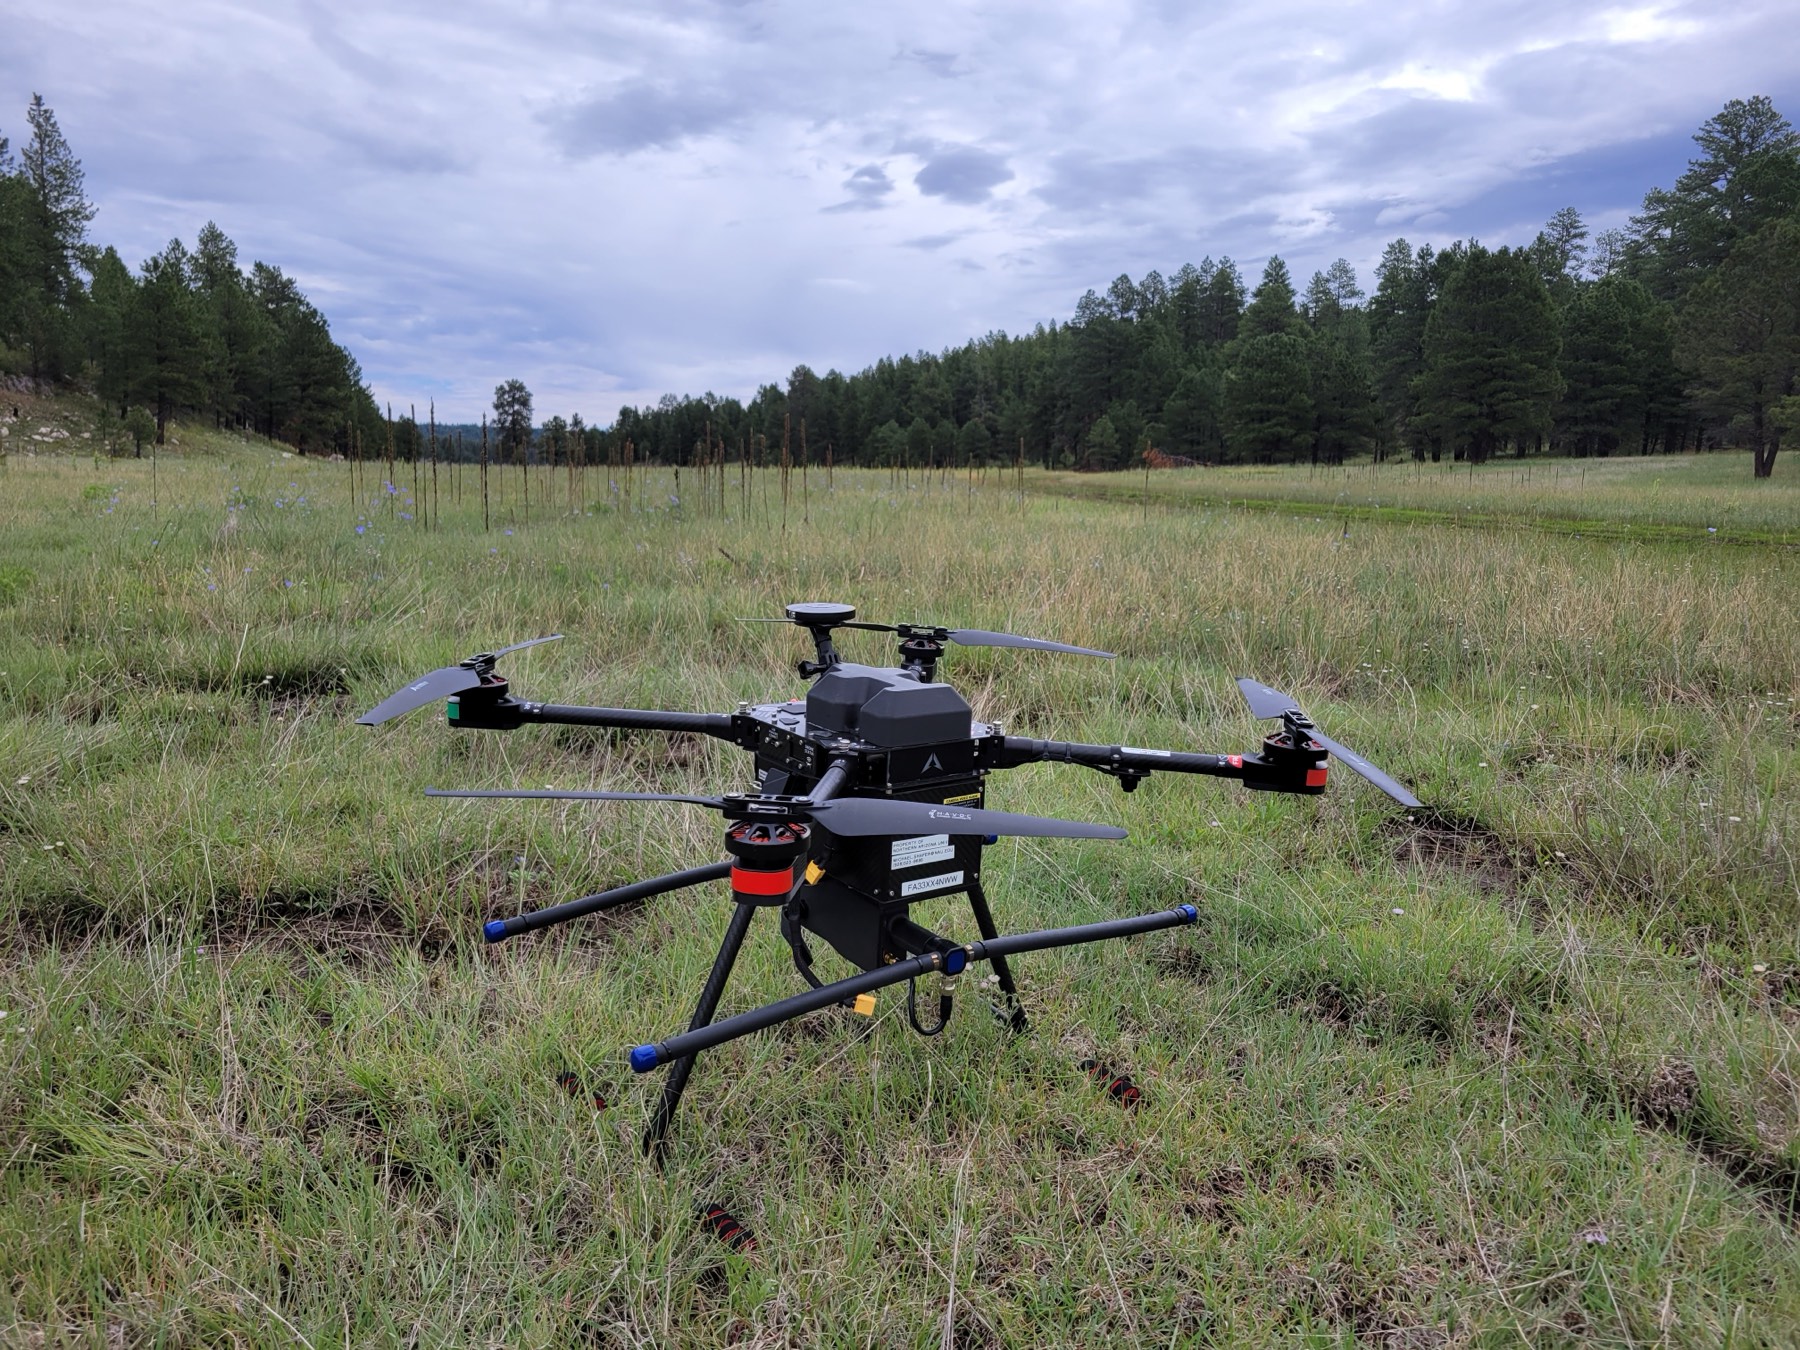
UAV-RT's home turf: original system development and testing near Flagstaff. We test here in various terrains and conducted early phase trials with Arizona Game & Fish tracking collared black-footed ferrets near Seligman.
Every deployment above produces per-detection GPS points colored by signal strength. We're building a browser-based tool to turn that into an interactive map — upload a CSV, see the search visually, export a KML. See the placeholder →
